Search This Supplers Products:Brushless DC MotorBrushed DC MotorJoint motorpolygon mirror motorwedge drive motorGalvanometer motor
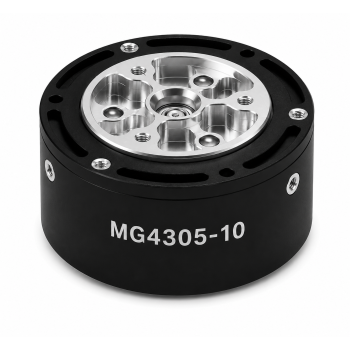
Elbow Joint Motor MG 4305-10 – BLDC Servo with 10:1 Planetary Gearbox


- group name
- Elbow Joint Motor
- Min Order
- 1 piece
- brand name
- Solismotor Custom Robot Joint Drives
- update time
- Tue, 22 Sep 2026 13:57:44 GMT
Paramtents
Model MG4305-10
Rated Torque 1.05N·m
Peak Torque 3.82N·m
Gear Ratio 10:1 Planetary
Encoder 14-Bit, Dual Support
Communication CAN Bus / RS485
Protection IP54
Weight ~150g
Dimension Ø53*32mm
Packging & Delivery
-
Min Order1 piece
Briefing
Detailed
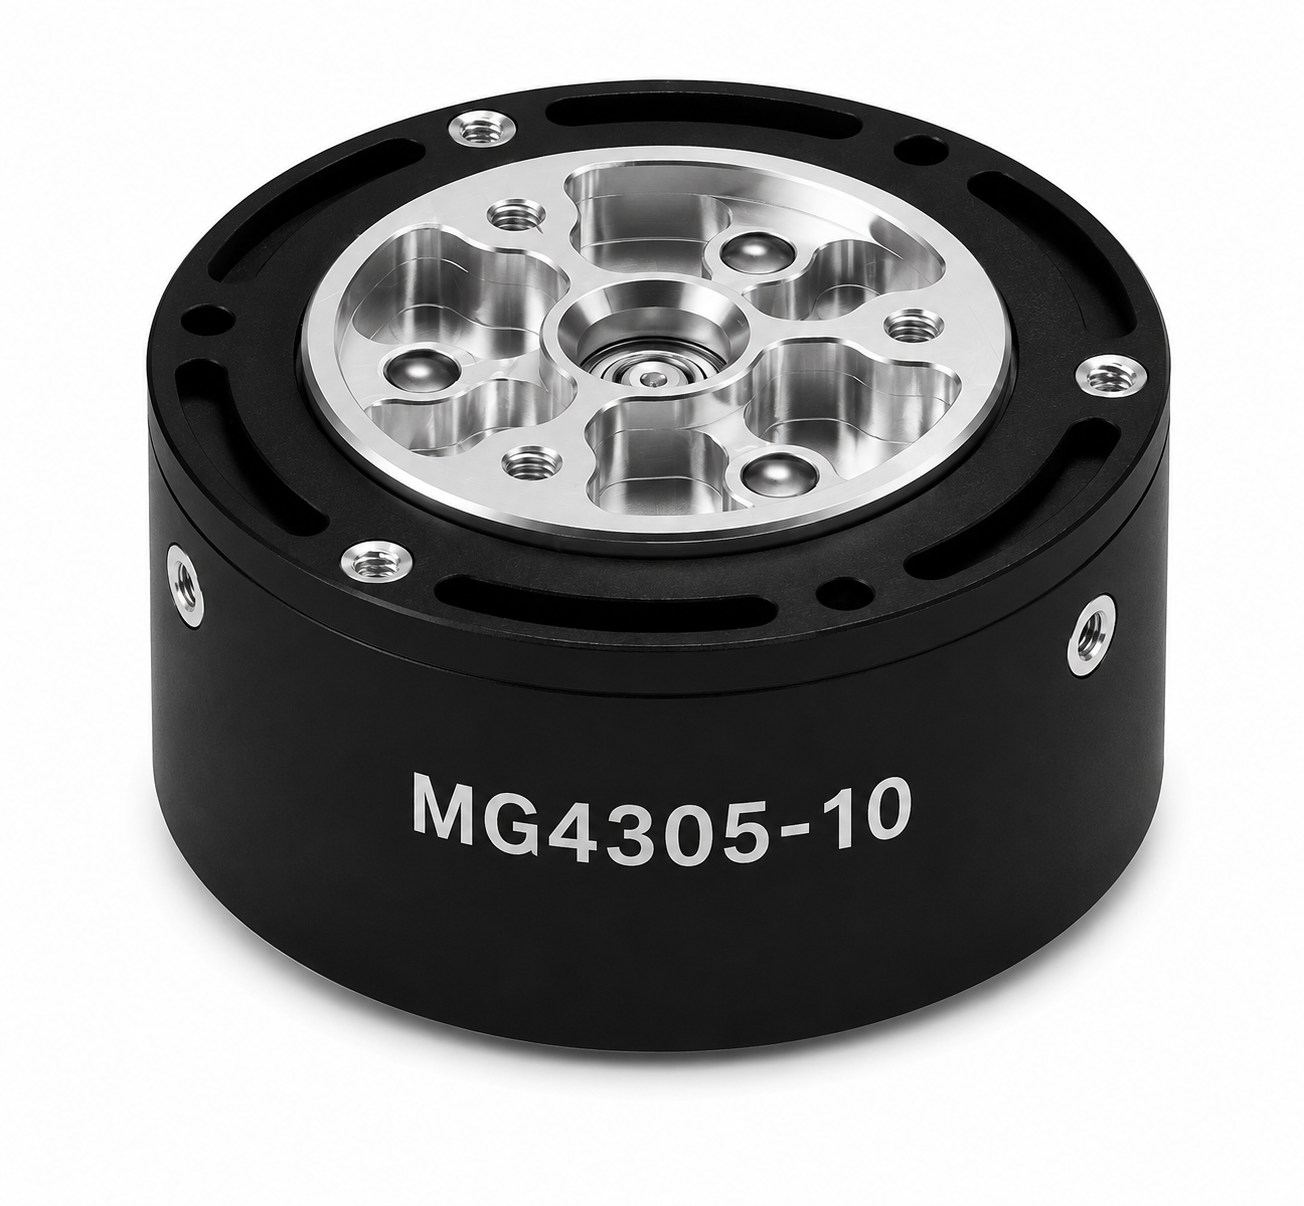
MG4305-10 Integrated Robot Joint Motor
The product integrates a high-performance brushless motor, a 10:1 precision planetary gear reduction mechanism, a high-precision encoder, and an intelligent drive control system. Within a compact and lightweight structure, it achieves high torque output, precise closed-loop control, and excellent dynamic response performance.
Engineered for Precision Motion
Feature – Integrated All-in-One Design
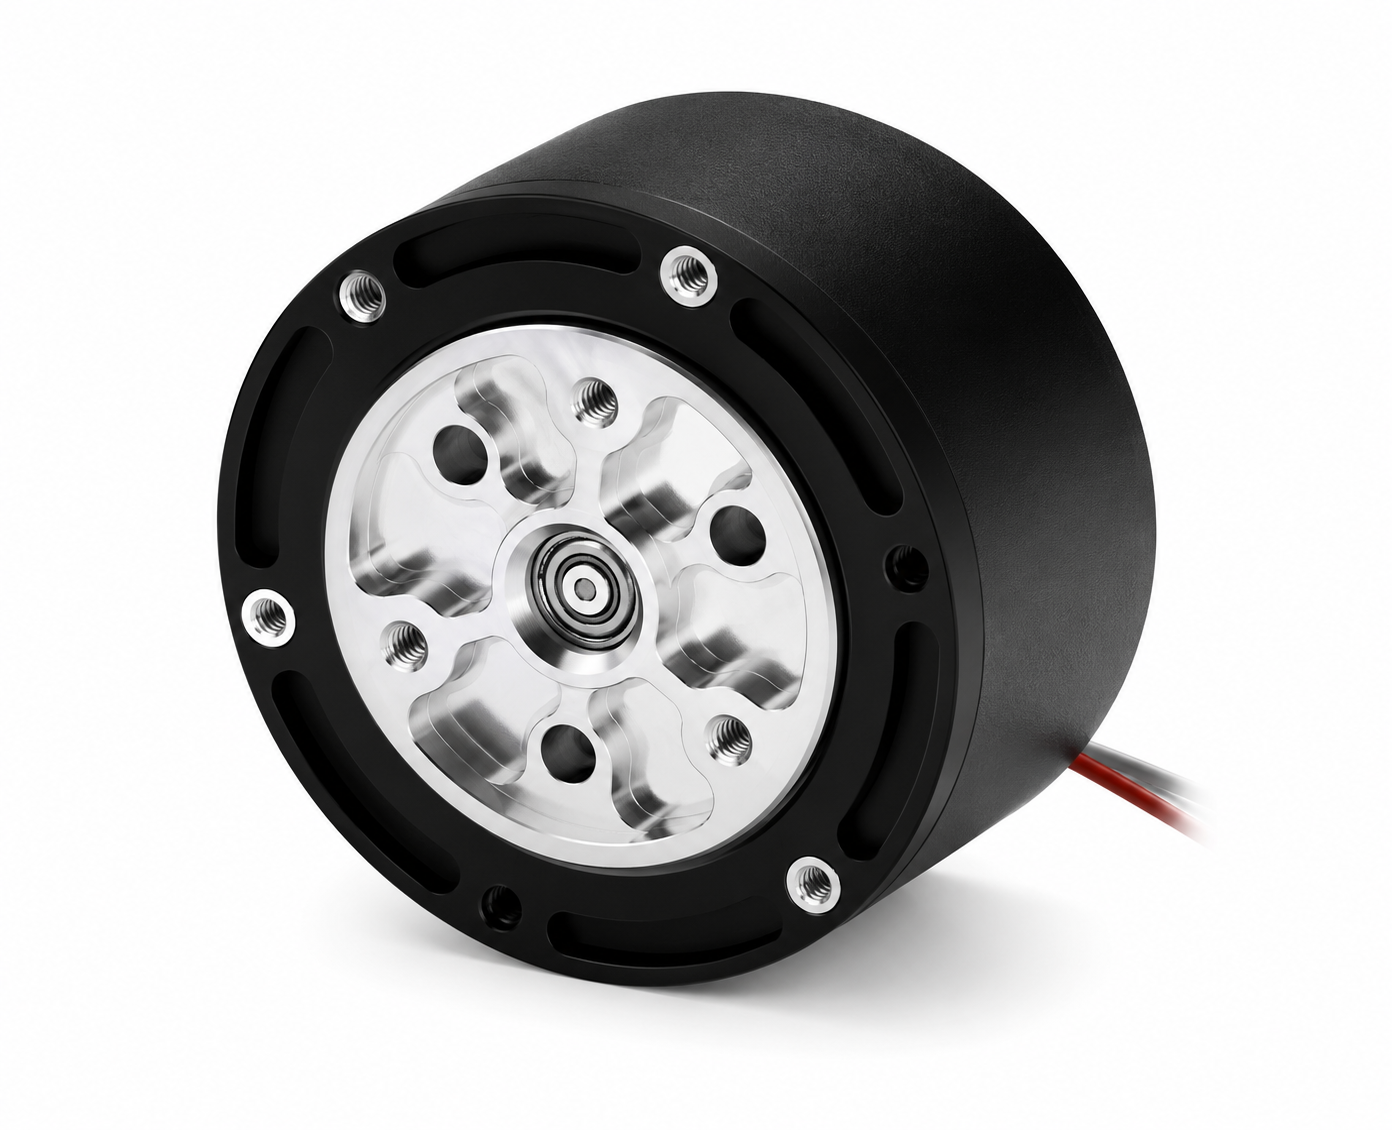
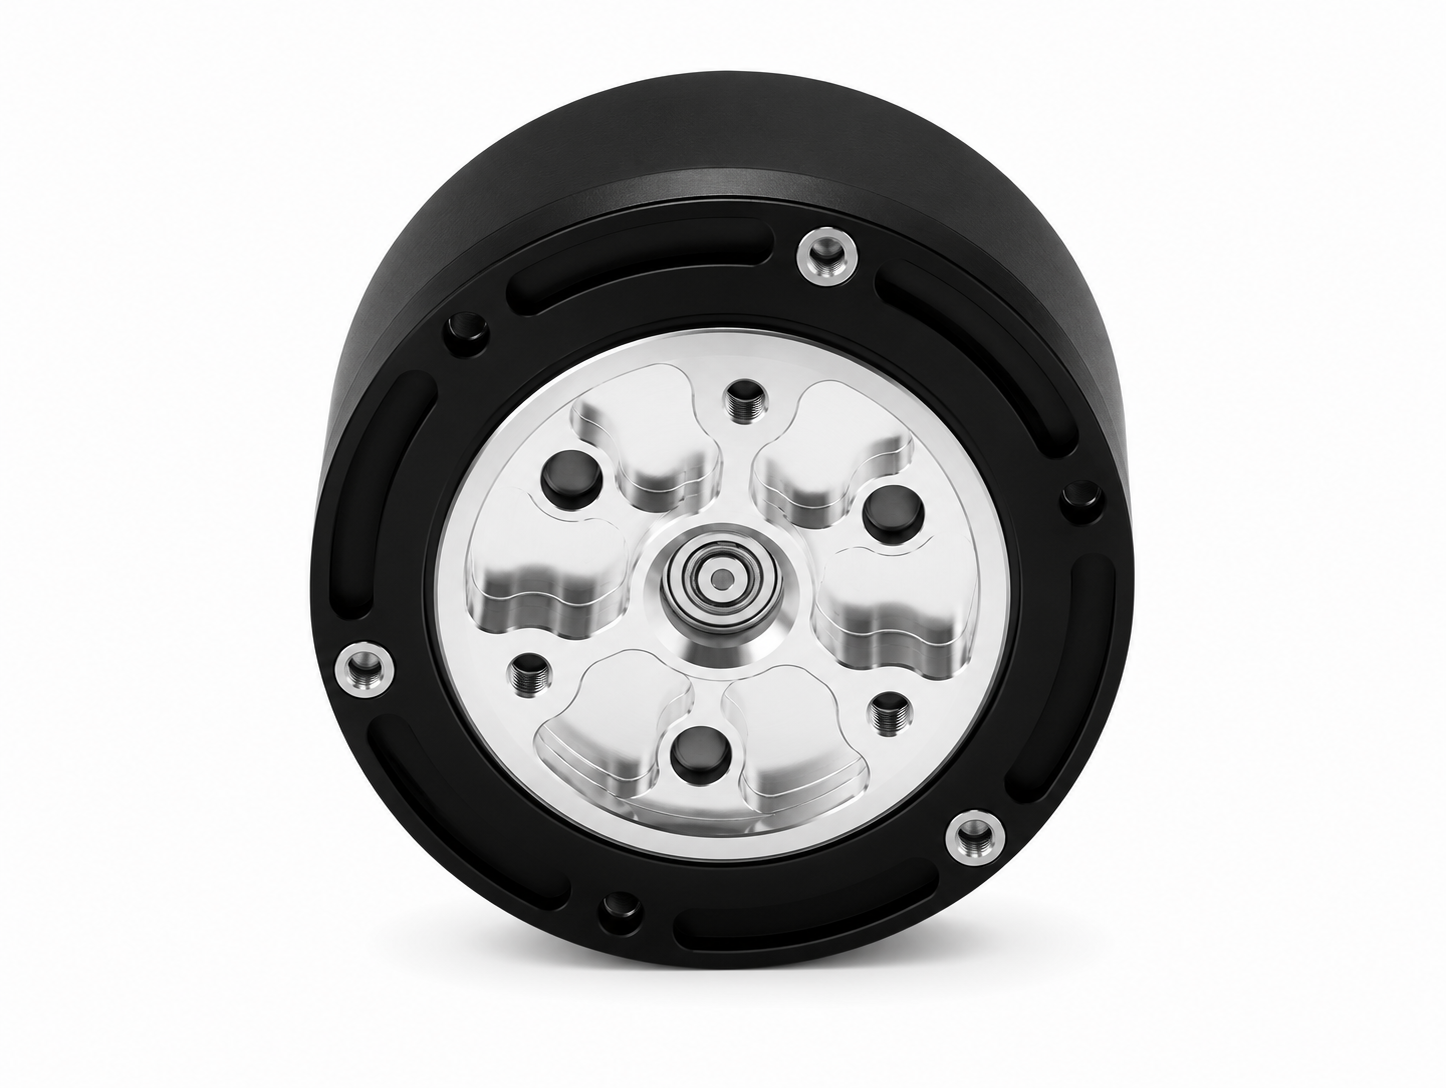
The MG4305-10 integrates a BLDC servo motor, 10:1 planetary gearbox, drive electronics, and dual encoders in a singleØ76*35mm housing. This eliminates the need for separate component sourcing, wiring, and tuning.
Advantage – Reduced System Complexity
By combining motor, gearbox, driver, and encoder into one module, engineers can cut development time by up to 60% and simplify overall system architecture significantly.
Benefit – Faster Time to Market
With plug-and-play integration, R&D teams can focus on application-level development rather than motor control, accelerating robot prototyping and production ramp-up.
Feature – High Torque Density
Rated output torque of 1.05N·m with peak stall torque reaching3.82N·m. The 10:1 planetary gearbox delivers exceptional torque density in a compact form factor.
Advantage – Superior Dynamic Performance
High torque-to-weight ratio enables faster acceleration, smoother motion, and greater load capacity — critical for responsive robot joint movement.
Benefit – Handles Demanding Applications
Suitable for humanoid robots, collaborative robots, and exoskeletons where high torque and compact size are essential for natural, powerful motion.
Feature – Dual Encoder Feedback & IP54 Protection
Built-in 14-bit high-resolution encoder with support for secondary encoder feedback on the output shaft. IP54-rated sealed housing protects against dust and water splashes.
Advantage – Precision & Reliability
Dual-loop feedback ensures accurate position, speed, and torque control. IP54 enables deployment in harsh industrial environments without performance degradation.
Benefit – Long-Term Operational Stability
Reliable feedback and environmental protection reduce maintenance needs and ensure consistent performance over extended operating periods.
Technical Specifications
Key Applications
Humanoid Robots
Joint actuation for bipedal and full-body humanoid platforms
Collaborative Robots
Safe, precise motion for cobot arms and grippers
Exoskeletons
Power assist and rehabilitation exoskeleton systems
Education & Research
Robotics labs, university projects, and prototyping
Medical Assistants
Surgical robots and rehabilitation equipment
Smart Automation
Automated guided vehicles and smart manufacturing